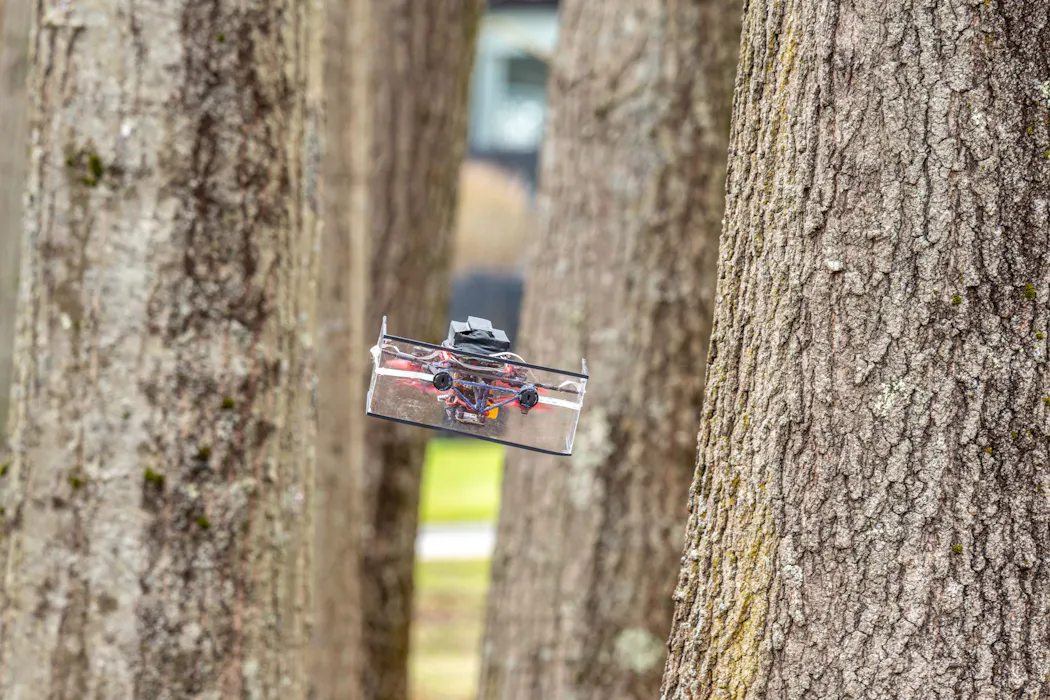
To help small aerial robots navigate in the dark and other low-visibility environments, my colleagues and I developed an ultrasound-based perception system inspired by bat echolocation.
Current robots rely heavily on cameras or light detection and ranging, known as lidar, or both. But these sensors fail in visually challenging conditions, such as smoke, fog, dust, snow or complete darkness.