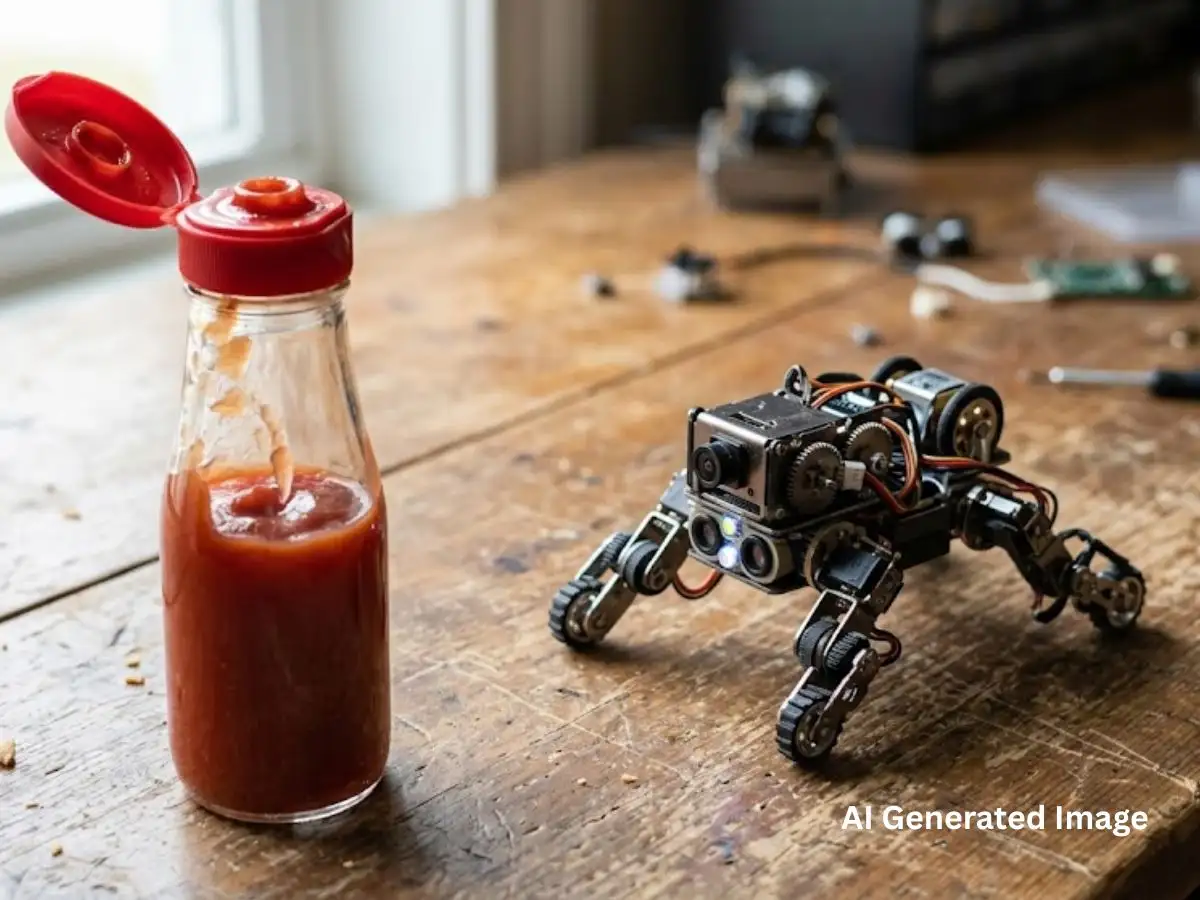
A familiar snap from a flip-top ketchup bottle has helped Princeton Engineering researchers uncover a broader principle in mechanical design. A team led by Glaucio Paulino studied how the curved hinge of a typical ketchup cap allows it to remain securely open or closed, then applied the same idea to curved, folded shells that can hold several stable shapes, TOI reported. The work ultimately led to a magnetically controlled robot that can roll, crawl and reconfigure itself without conventional motors or complex internal mechanisms.
The hinge of a standard flip-top cap connects a thin, flexible shell to a thicker, rigid base along a curved boundary. This arrangement creates two stable positions, with an energy barrier between them that must be crossed for the cap to move from one state to the other. The researchers used this simple example to investigate how curved shells could similarly maintain multiple configurations without relying on traditional locking systems.